The LKIMM ELE360 is an all electric injection molding machine designed for the fast injection molding of thin-wall containers, medical parts etc.. With a clamping
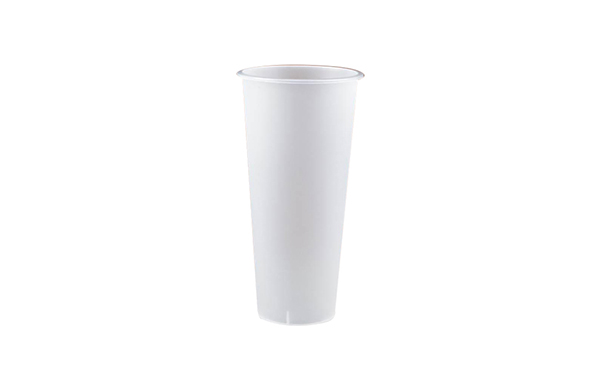
force up to 3600kN and an opening stroke of 720mmm, the LKIMM ELE360 is suitable for the injection molding production of 700ml beverages up to 8 cavities. With a dry cycle time of 3.3s and
an in mold time lowered to 0.7s, SWITEK SW7112DS is one of the best picking robot for such a project.
The Features of LKIMM ELE360 All Electric Injection Molding Machine
IN GENERAL
Efficient: multi-action synchronization, high response, and high speed, reducing the cycle time by 30%.
Quite: Noise level at least 10dB lower than hydraulic machines.
Safe: Mechanical safety; Electrical safety; Program safety; (Dual protection: full closed-loop program control and machine safety
interlock for enhanced operational security)
Clean: GMB-grade cleanliness.
Intelligent: High computing controller; EU-77 compliant OPC-UA communication protocol open platform, enabling secondary editing
and development.
Precise: Precise motor control, with accuracy up to 0.01mm Manufacturing weight deviation ≤0.1%.
Energy-saving: Over 30% more energy-efficient than conventional hydraulic machines.
CLAMPING UNIT
Clamping position control accuracy reaches 0.01mm.
The dry cycle is short, with a maximum mold opening/closing speed of up to 1,000mm/s.
Linear guides offr Excellent guiding performance with low energy consumption.
Non-contact tie bars provide high cleanliness.
INJECTION UNIT
The manufacturing weight deviation is ±0.1%.
4 VP switching functions are available: time, position, pressure, and mold pressure signal.
The injection acceleration reaches 1G.
Linear guides offer excellent guiding performance with low energy consumption.
CONTROL UNIT
The system utilizes Intel high-performance processors and adopts full dosedloop control, achieving 0.01mm axis accuracy and
maintaining pressure deviation within 0.1MPa.
With 4GB DDR4 and SSD 512GB, it can store process data for 5 million molds, parameters for 5,000mold sets, and 100,000 operation
seconds. The system supports batch import/export of Excel and PDF files.
The self-developed application software incorporates proprietary core technologies and supports customized software functions,
delivering maximum productivity.
OPC-UA and Modbus compatibility enables production line data collection and processing, along with customized data services.
More Stable Process Control: The barrel temperature is controlled within ±0.5°C under steady-state conditions. The
overshoot of injection pressure control is ≤5%, with steady-state fluctuations of ≤0.5 Bar.
Controllable Process Data: A high-sampling-rate osalloscope with real-time sampling for process optimization and comparative analysis.
Support for IOT remote data collecting and service*. Fast response for technicians to solve customers concern online.
Why is SWITEK SW7112DS One of the Best Fast Picking Robot for LKIMM ELE360 All Electric Injection Molding Machine?
As a high speed 3 axis servo robotic arm designed for the fast picking of thin-wall containers from the injectin molding machine, the advantages
below make it one of the best picking robot for the LKIMM ELE360 High Speed injection molding machine:
Dry cycle time lowered to 3.3s.
With in mold time lowered to 0.7s.
Suitable for injection molding machine with clamping force from 2000kN to 5000kN.
User friendly interface, easy operating with lower training cost.
With the main components made by big names, lower maintenance cost.
Optional EU12/EU67/JIS interface, easy connection to the injection molding machine.
Parameters of SWITEK SW7112DS High Speed Picking Robot
Tips of Robot Selecting for Your Injection Molding Machine
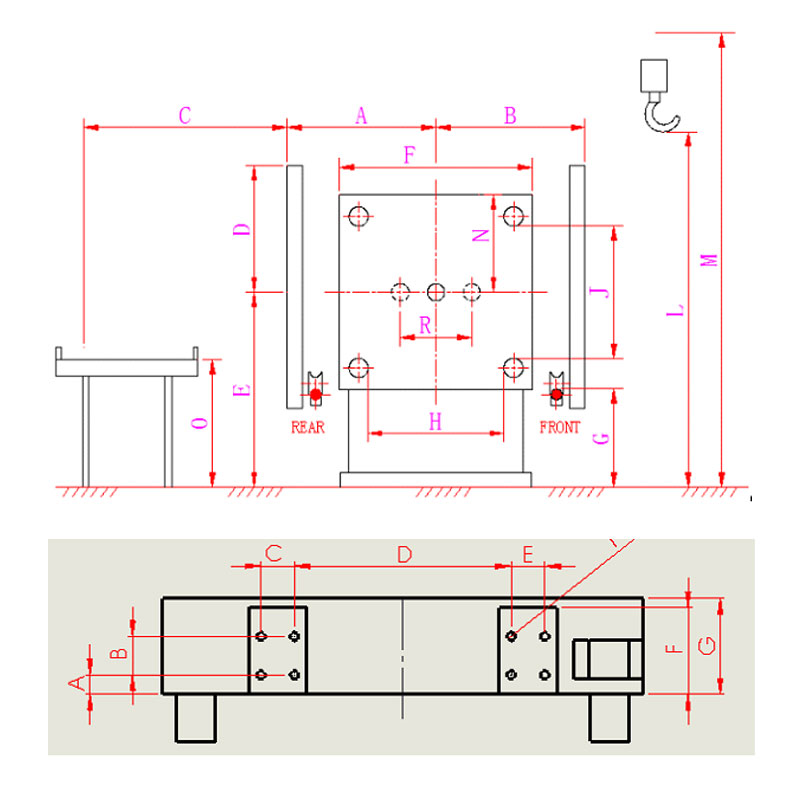
The height of the robotic arm + the height of the injection molding machine < the height of the crane L;
The vertical stroke of the robotic arm (Y) will reach the mold center;
The EOAT will reach a height over the safe door (D-N);
The crosswise stroke (X2) is sufficient to pick the parts from the movable platen of the injection molding machine;
The traverse stroke (Z) is long enough to place the parts on the conveyor (B+C for operator side parts dropping or A+C for non-operator
side parts dropping);
The robot has sufficient payload to load the right EOAT for parts picking;
To install an A/B/C servo posture for the parts picking from a complex structure mold;
The robot has a correct interface (EU12/EU67/JIS) to communicate with the injection molding machine;
The robot has sufficient I/O reservation for complex EOAT or automation integration;