The WELLTEC 353SEc is a high speed injection molding machine designed for the fast injection molding of thin-wall containers. With a clamping
force up to 3530kN and an opening stroke of 650mmm, the WELLTEC 353SEc is suitable for the injection molding production of 700ml beverages up to 8 cavities. With a dry cycle time of 3.3s and
an in mold time lowered to 0.7s, SWITEK SW7112DS is one of the best picking robot for such a project.
The Features of WELLTEC 353SEc High Speed Injection Molding Machine
High rigidity clamping structure equipped with linear slide rail and proportional valve is more suitable for high speed system.
The special stress-relief groove of tie bar is designed to disperse the clamping stress and avoid breaking.
Injection by single cylinder to effectively avoid breaking of injection screw and piston which are commonly seen in the imbalanced
double-cylinder injection designs.
The design of the clamping toggle has been optimized to follow high-speed motion curve, and reduce stress for mould open/close which
avoids damaging the toggle.
Stresses are evenly distributed through the platens and the center of the mould, high platen-parallelism to minimize flashes and reduce the
demand for clamping force.
Stress-reducing mould platen designs to help maintaining platen-parallelism effectively and delivering products with even thickness.
Austrian made, B&R professional control system designed for injection moulding machine, equipped with high-speed control program, 10.4-inch colour
screen and network data inteface. Providing excellent HMI user-friendliness.
Optimised mould platen reduces deformation and stress. It improves durability to cater to high precision injection moulding.
High-speed and stable hydraulic circuits for mould open/close to achieve very sensitive and low-pressure mould protection. Hydraulic components of
renowned brands to ensure high repeatability in mould open/close position accuracy of ±0.15mm.
High response servo system is supported by —— High response, low interia and high KT value special servo motor, 30ms perfect acceleration
(0-2000rpm) together with the seamless connection by high response CAN communication servo driver and the special control system.
Why is SWITEK SW7112DS One of the Best Fast Picking Robot for WELLTEC 353SEc High Speed Injection Molding Machine?
As a high speed 3 axis servo robotic arm designed for the fast picking of thin-wall containers from the injectin molding machine, the advantages
below make it one of the best picking robot for the WELLTEC 353SEc high speed injection molding machine:
Dry cycle time lowered to 3.3s.
With in mold time lowered to 0.7s.
Suitable for injection molding machine with clamping force from 2000kN to 5000kN.
User friendly interface, easy operating with lower training cost.
With the main components made by big names, lower maintenance cost.
Optional EU12/EU67/JIS interface, easy connection to the injection molding machine.
Parameters of SWITEK SW7112DS High Speed Picking Robot
Tips of Robot Selecting for Your Injection Molding Machine
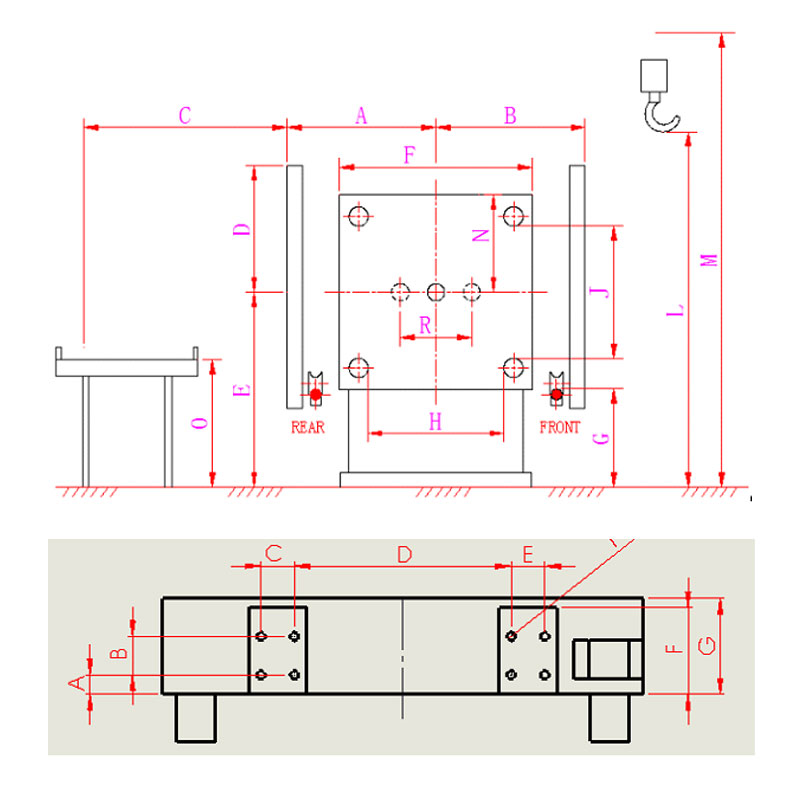
The height of the robotic arm + the height of the injection molding machine < the height of the crane L;
The vertical stroke of the robotic arm (Y) will reach the mold center;
The EOAT will reach a height over the safe door (D-N);
The crosswise stroke (X2) is sufficient to pick the parts from the movable platen of the injection molding machine;
The traverse stroke (Z) is long enough to place the parts on the conveyor (B+C for operator side parts dropping or A+C for non-operator
side parts dropping);
The robot has sufficient payload to load the right EOAT for parts picking;
To install an A/B/C servo posture for the parts picking from a complex structure mold;
The robot has a correct interface (EU12/EU67/JIS) to communicate with the injection molding machine;
The robot has sufficient I/O reservation for complex EOAT or automation integration;